Publications

2026

OpenJaws: An Open Hardware UMI Framework with Stereo Localization for Generalist Manipulation

A. Murali, Y. Oza, K. Chahal, N. Jawale, S. De Vries, H. Rabeti, E. Coumans, B. Sundaralingam, S. Birchfield

arXiv:2610.36598

GATOR: Generative and Agentic 3D Object Reconstruction From Casual Images

Q. Wu, S. Birchfield, H. Rabeti, A. X. Chang, B. Wen

arXiv:2610.11215

Hydra-0: Action Flow for Generalist World Modeling and Control

H. Li, B. Wen, X. Zhu, Y. Wang, Y. Du, Y. Li, G. Konidaris, S. Birchfield, S. Pouya, C. Li, Y. Chang

arXiv:2608.18077

MG-VQA: Manipulation Grounded Visual Question Answering with VLMs

V. Bhat, M. A. Uy, S. Chen, A. Zook, X. Yang, S. Birchfield, V. Blukis, J. Tremblay

arXiv:2608.17129

Vesta: A Generalist Embodied Reasoning Model

J. Bjorck, Z. Li, Y. Man, J. Wang, A.-C. Cheng, S. Liu, S. Wang, Z. Yu, A. Badki, S. Birchfield, V. Blukis, Y. Chebotar, S. Chen, S. Leng, Y.-C. Chou, T. Ding, B. Li, Z. Luo, H. Su, J. Tremblay, T. Wang, B. Wen, J. Wu, X. Xie, H. Ye, H. Yin, K. R. Zentner, L. Gui, Y.-X. Wang, Y. Zhu, L. Fan, J. Kautz

arXiv:2606.20905

See What I See, Know What I Think: Dense Latent Communication Across Heterogeneous Agents

S. Chen, X. Zhang, M. Wu, J. Tremblay, V. Blukis, S. Birchfield, R. Vidal, A. Velasquez, S. Liu, Q. Qu

arXiv:2606.13594

cuRoboV2: Dynamics-Aware Motion Generation with Depth-Fused Distance Fields for High-DoF Robots

B. Sundaralingam, A. Murali, S. Birchfield

arXiv:2603.05493

PointZero: 3D Point Track Completion for Learning Transferable 3D Dynamics

B. P. Duisterhof, K. Zhang, A. Hung, B. Wen, Stan Birchfield, Y. Li, D. Ramanan, J. Ichnowski

Neural Information Processing Systems (NeurIPS), Sydney/Atlanta/Paris, December 2026

VoLo: A Physical Orchestrator for Open-Vocabulary Long-Horizon Manipulation

S. Chen, H. Hadfield, A. Zook, M. A. Uy, C. H. Song, E. Coumans, X. Yang, F. Ladhak, Q. Qu, S. Birchfield, J. Tremblay, V. Blukis

Conference on Robot Learning (CoRL), Austin, Texas, November 2026

OG-VLA: 3D-Aware Vision Language Action Model via Orthographic Image Generation

I. Singh, A. Goyal, S. Birchfield, D. Fox, A. Garg, V. Blukis

International Conference on Intelligent Robots and Systems (IROS), Pittsburgh, October 2026

RoboLab: A High-Fidelity Simulation Benchmark for Analysis of Task Generalist Policies

X. Yang, R. Dagli, A. Zook, H. Hadfield, A. Goyal, S. Birchfield, F. Ramos, J. Tremblay

Robotics Science and Systems (RSS), Sydney, Australia, July 2026

Press: NVIDIA blog post

SpaceTools: Tool-Augmented Spatial Reasoning via Double Interactive RL

S. Chen, M. A. Uy, C. H. Song, F. Ladhak, A. Murali, Q. Qu, S. Birchfield, V. Blukis, J. Tremblay

Computer Vision and Pattern Recognition (CVPR), Denver, Colorado, June 2026

Also in CVPR Workshop on Multimodal Spatial Intelligence (MUSI), Denver, Colorado, June 2026

CARI4D: Category Agnostic 4D Reconstruction of Human-Object Interaction

X. Xie, B. Wen, Y. Chang, H. Rabeti, J. Li, Y. Yuan, G. Pons-Moll, S. Birchfield

Computer Vision and Pattern Recognition (CVPR), Denver, Colorado, June 2026

Also in CVPR Workshop on Agents in Interactions: From Humans to Robots, Denver, Colorado, June 2026

Fast-FoundationStereo: Real-Time Zero-Shot Stereo Matching

B. Wen, S. R. Dewan, S. Birchfield

Computer Vision and Pattern Recognition (CVPR), Denver, Colorado, June 2026

BOP-ASK: Object-Interaction Reasoning for Vision-Language Models

V. Bhat, S. Kim, V. Blukis, G. Heinrich, P. Krishnamurthy, R. Karri, S. Birchfield, F. Khorrami, J. Tremblay

Computer Vision and Pattern Recognition (CVPR), Denver, Colorado, June 2026

GraspGen-X: Cross-Embodiment 6-DOF Diffusion-based Grasping

B. Han, Y.-W. Chao, E. Coumans, C. Eppner, J. Deng, S. Birchfield, A. Murali

Computer Vision and Pattern Recognition (CVPR), Denver, Colorado, June 2026

Press: NVIDIA blog post

GraspGen: A Diffusion-based Framework for 6-DOF Grasping with On-Generator Training

A. Murali, B. Sundaralingam, Y.-W. Chao, W. Yuan, J. Yamada, M. Carlson, F. Ramos, S. Birchfield, D. Fox, C. Eppner

International Conference on Robotics and Automation (ICRA), Vienna, Austria, June 2026

3D-Generalist: Self-Improving Vision-Language-Action Models for Crafting 3D Worlds

F.-Y. Sun, S. Wu, C. Jacobsen, T. Yim, H. Zou, A. Zook, S. Li, Y.-H. Chou, E. Can, X. Wu, C. Eppner, V. Blukis, J. Tremblay, J. Wu, S. Birchfield, N. Haber

International Conference on 3D Vision (3DV), Vancouver, Canada, March 2026

2025

RaySt3R: Predicting Novel Depth Maps for Zero-Shot Object Completion

B. P. Duisterhof, J. Oberst, B. Wen, S. Birchfield, D. Ramanan, J. Ichnowski

Neural Information Processing Systems (NeurIPS), San Diego, December 2025

FoundationStereo: Zero-Shot Stereo Matching

B. Wen, M. Trepte, J. Aribido, J. Kautz, O. Gallo, S. Birchfield

Computer Vision and Pattern Recognition (CVPR), Nashville, Tennessee, June 2025

Award: CVPR Best Paper Award Candidate

News: #1 on Middlebury Stereo Evaluation - Version 3 (2025/02/03 – 2025/03/04)

News: #1 on ETH3D Low-Res Two-View Benchmark (2024/11/15 – 2025/05/14)

RoboSpatial: Teaching Spatial Understanding to 2D and 3D Vision-Language Models for Robotics

C. H. Song, V. Blukis, J. Tremblay, S. Tyree, Y. Su, S. Birchfield

Computer Vision and Pattern Recognition (CVPR), Nashville, Tennessee, June 2025

Also in CVPR Workshop on Emergent Visual Abilities and Limits of Foundation Models (EVAL-FoMo-2), Nashville, Tennessee, June 2025

Also in CVPR Workshop on 3D-LLM/VLA, Nashville, Tennessee, June 2025

Also in ICLR Workshop on Robot Learning: Towards Robots with Human-Level Abilities, Singapore, April 2025

Also in CoRL Workshop on GenPriors, Seoul, Korea, September 2025

SPOT: SE(3) Pose Trajectory Diffusion for Object-Centric Manipulation

C.-C. Hsu, B. Wen, J. Xu, Y. Narang, X. Wang, Y. Zhu, J. Biswas, S. Birchfield

International Conference on Robotics and Automation (ICRA), Atlanta, May 2025

Audio-Visual Segmentation with Semantics

J. Zhou, X. Shen, J. Wang, J. Zhang, W. Sun, J. Zhang, S. Birchfield, D. Guo, L. Kong, M. Wang, Y. Zhong

International Journal of Computer Vision (IJCV), 133(4):1644-1664, April 2025

BOP Challenge 2024 on Model-Based and Model-Free 6D Object Pose Estimation

V. N. Nguyen, S. Tyree, A. Guo, M. Fourmy, A. Gouda, T. Lee, S. Moon, H. Son, L. Ranftl, J. Tremblay, E. Brachmann, B. Drost, V. Lepetit, C. Rother, S. Birchfield, J. Matas, Y. Labbe, M. Sundermeyer, T. Hodan

CVPR Workshop on Computer Vision for Mixed Reality (CV4MR), Nashville, Tennessee, June 2025

Award: CV4MR Workshop Best Paper Award

Robot Policy Evaluation for Sim-to-Real Transfer: A Benchmarking Perspective

X. Yang, C. Eppner, J. Tremblay, D. Fox, S. Birchfield, F. Ramos

RSS Workshop on Robot Evaluation for the Real World, Los Angeles, June 2025

Towards a VLM Benchmark for Simulated Robotics

X. Yang, C. Eppner, V. Blukis, P. Belcak, S. Tyree, D. Fox, S. Birchfield, F. Ramos, J. Tremblay

RSS Workshop on Large Foundation Model for Interactive Robot Learning (LFM), Los Angeles, June 2025

GRS: Generating Robotic Simulation Tasks from Real-World Images

A. Zook, F.-Y. Sun, J. Spjut, V. Blukis, S. Birchfield, J. Tremblay

CVPR Workshop on Computer Vision for Video Games (CV2), Nashville, Tennessee, June 2025

Mitigating Covariate Shift in Imitation Learning for Autonomous Vehicles Using Latent Space Generative World Models

A. Popov, A. Degirmenci, D. Wehr, S. Hegde, R. Oldja, A. Kamenev, B. Douillard, D. Nistér, U. Muller, R. Bhargava, S. Birchfield, N. Smolyanskiy

ICRA Workshop on Robots in the Wild, Atlanta, May 2025

Pushing Buttons: Aligning Humanoid Real2Sim2Real via Active Perception

R.-Z. Qiu, B. Wen, Y. Jiang, C. Tessler, E. Heiden, X. B. Peng, X. Wang, S. Birchfield, E. Coumans

2025

2024

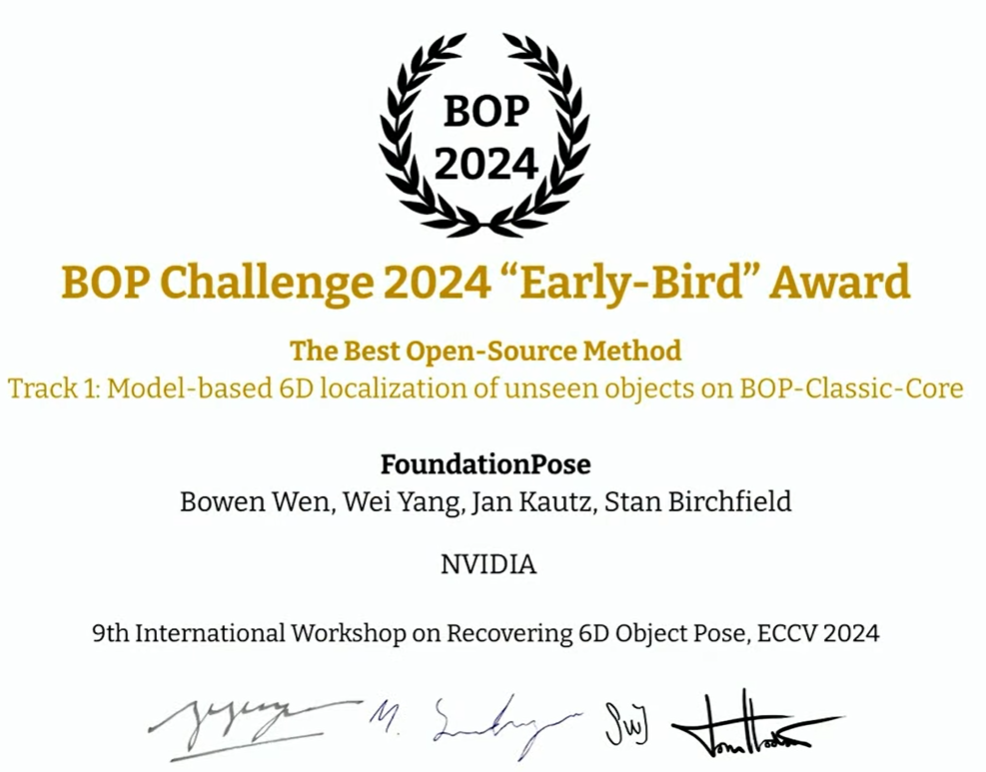
FoundationPose: Unified 6D Pose Estimation and Tracking of Novel Objects

B. Wen, W. Yang, J. Kautz, S. Birchfield

Computer Vision and Pattern Recognition (CVPR), Seattle, June 2024

Award: BOP Challenge 2024 "Early Bird" Award

News: #1 on BOP leaderboard for unseen 6D pose estimation (2023/11/19 – 2024/09/03)

Press: NVIDIA AI post, NVIDIA blog on TAO Foundation Models

Neural Implicit Representation for Building Digital Twins of Unknown Articulated Objects

Y. Weng, B. Wen, J. Tremblay, V. Blukis, D. Fox, L. Guibas, S. Birchfield

Computer Vision and Pattern Recognition (CVPR), Seattle, June 2024

NeRFDeformer: NeRF Transformation from a Single View via 3D Scene Flows

Z. Tang, Z. Ren, X. Zhao, B. Wen, J. Tremblay, S. Birchfield, A. Schwing

Computer Vision and Pattern Recognition (CVPR), Seattle, June 2024

DeformGS: Scene Flow in Highly Deformable Scenes for Deformable Object Manipulation

B. P. Duisterhof, M. Zhao, Y. Yao, J.-W. Liu, J. Seidenschwarz, M. Z. Shou, D. Ramanan, S. Song, S. Birchfield, B. Wen, J. Ichnowski

Workshop on the Algorithmic Foundations of Robotics (WAFR), Chicago, October 2024

Partial-View Object View Synthesis via Filtered Inversion

F.-Y. Sun, J. Tremblay, V. Blukis, K. Lin, D. Xu, B. Ivanovic, P. Karkus, S. Birchfield, D. Fox, R. Zhang, Y. Li, J. Wu, M. Pavone, N. Haber

3DV, Davos, Switzerland, March 2024

Also in CVPR Workshop on Advances in NeRF for the Metaverse (XRNeRF), Vancouver, June 2023

Unlocking the Secrets of Linear Complexity Sequence Model from A Unified Perspective

Z. Qin, X. Shen, W. Sun, D. Li, S. Birchfield, R. Hartley, Y. Zhong

ICML Workshop on Next Generation of Sequence Modeling Architectures, Vienna, Austria, July 2024

2023

HANDAL: A Dataset of Real-World Manipulable Object Categories with Pose Annotations, Affordances, and Reconstructions

A. Guo, B. Wen, J. Yuan, J. Tremblay, S. Tyree, J. Smith, S. Birchfield

International Conference on Intelligent Robots and Systems (IROS), Detroit, Michigan, October 2023

BundleSDF: Neural 6-DoF Tracking and 3D Reconstruction of Unknown Objects

B. Wen, J. Tremblay, V. Blukis, S. Tyree, T. Müller, A. Evans, D. Fox, J. Kautz, S. Birchfield

Computer Vision and Pattern Recognition (CVPR), Vancouver, June 2023

Press: NVIDIA 3D object reconstruction workflow post

TTA-COPE: Test-Time Adaptation for Category-Level Object Pose Estimation

T. Lee, J. Tremblay, V. Blukis, B. Wen, B.-U. Lee, I. Shin, S. Birchfield, I. S. Kweon, K.-J. Yoon

Computer Vision and Pattern Recognition (CVPR), Vancouver, June 2023

Affordance Diffusion: Synthesizing Hand-Object Interactions

Y. Ye, X. Li, A. Gupta, S. De Mello, S. Birchfield, J. Song, S. Tulsiani, S. Liu

Computer Vision and Pattern Recognition (CVPR), Vancouver, June 2023

Parallel Inversion of Neural Radiance Fields for Robust Pose Estimation

Y. Lin, T. Müller, J. Tremblay, B. Wen, S. Tyree, A. Evans, P. A. Vela, S. Birchfield

International Conference on Robotics and Automation (ICRA), London, May 2023

RGB-Only Reconstruction of Tabletop Scenes for Collision-Free Manipulator Control

Z. Tang, B. Sundaralingam, J. Tremblay, B. Wen, Y. Yuan, S. Tyree, C. Loop, A. Schwing, S. Birchfield

International Conference on Robotics and Automation (ICRA), London, May 2023

One-Shot Neural Fields for 3D Object Understanding

V. Blukis, T. Lee, J. Tremblay, B. Wen, I. S. Kweon, K.-J. Yoon, D. Fox, S. Birchfield

CVPR Workshop on Advances in NeRF for the Metaverse (XRNeRF), Vancouver, June 2023

Vicinity Vision Transformer

W. Sun, Z. Qin, H. Deng, J. Wang, Y. Zhang, K. Zhang, N. Barnes, S. Birchfield, L. Kong, Y. Zhong

IEEE Transactions on Pattern Analysis and Machine Intelligence (PAMI), 45(10):12635-12649, October 2023

Diff-DOPE: Differentiable Deep Object Pose Estimation

J. Tremblay, B. Wen, V. Blukis, B. Sundaralingam, S. Tyree, S. Birchfield

arXiv:2310.00463, October 2023

2022

MegaPose: 6D Pose Estimation of Novel Objects via Render & Compare

Y. Labbé, L. Manuelli, A. Mousavian, S. Tyree, S. Birchfield, J. Tremblay, J. Carpentier, M. Aubry, D. Fox, J. Sivic

Conference on Robot Learning (CoRL), Auckland, New Zealand, December 2022

6-DoF Pose Estimation of Household Objects for Robotic Manipulation: An Accessible Dataset and Benchmark

S. Tyree, J. Tremblay, T. To, J. Cheng, T. Mosier, J. Smith, S. Birchfield

International Conference on Intelligent Robots and Systems (IROS), Kyoto, Japan, October 2022

Audio-Visual Segmentation

J. Zhou, J. Wang, J. Zhang, W. Sun, J. Zhang, S. Birchfield, D. Guo, L. Kong, M. Wang, Y. Zhong

European Conference on Computer Vision (ECCV), Tel-Aviv, Israel, October 2022

PredictionNet: Real-Time Joint Probabilistic Traffic Prediction for Planning, Control, and Simulation

A. Kamenev, L. Wang, O. B. Bohan, I. Kulkarni, B. Kartal, A. Molchanov, S. Birchfield, D. Nistér, N. Smolyanskiy

International Conference on Robotics and Automation (ICRA), Philadelphia, Pennsylvania, May 2022

Single-Stage Keypoint-Based Category-Level Object Pose Estimation from an RGB Image

Y. Lin, J. Tremblay, S. Tyree, P. A. Vela, S. Birchfield

International Conference on Robotics and Automation (ICRA), Philadelphia, Pennsylvania, May 2022

Keypoint-Based Category-Level Object Pose Tracking from an RGB Sequence with Uncertainty Estimation

Y. Lin, J. Tremblay, S. Tyree, P. A. Vela, S. Birchfield

International Conference on Robotics and Automation (ICRA), Philadelphia, Pennsylvania, May 2022

Displacement-Invariant Cost Computation for Stereo Matching

Y. Zhong, C. Loop, W. Byeon, S. Birchfield, Y. Dai, K. Zhang, A. Kamenev, T. Breuel, H. Li, J. Kautz

International Journal of Computer Vision (IJCV), 130(5):1196-1209, May 2022

RTMV: A Ray-Traced Multi-View Synthetic Dataset for Novel View Synthesis

J. Tremblay*, M. Meshry*, A. Evans, J. Kautz, A. Keller, S. Khamis, C. Loop, N. Morrical, T. Müller, K. Nagano, T. Takikawa, S. Birchfield

ECCV Workshop on Learning to Generate 3D Shapes and Scenes, Tel-Aviv, Israel, October 2022

2021

Self-Supervised Real-to-Sim Scene Generation

A. Prakash, S. Debnath, J.-F. Lafleche, S. Birchfield, E. Cameracci, G. State, M. T. Law

International Conference on Computer Vision (ICCV), Montreal, Canada, October 2021 (virtual)

Joint Space Control via Deep Reinforcement Learning

V. Kumar, D. Hoeller, B. Sundaralingam, J. Tremblay, S. Birchfield

International Conference on Intelligent Robots and Systems (IROS), Prague, Czech Republic, September 2021 (virtual)

Multi-View Fusion for Multi-Level Robotic Scene Understanding

Y. Lin, J. Tremblay, S. Tyree, P. A. Vela, S. Birchfield

International Conference on Intelligent Robots and Systems (IROS), Prague, Czech Republic, September 2021 (virtual)

Deep Two-View Structure-from-Motion Revisited

J. Wang, Y. Zhong, Y. Dai, S. Birchfield, K. Zhang, N. Smolyanskiy, H. Li

Computer Vision and Pattern Recognition (CVPR), Nashville, Tennessee, June 2021 (virtual)

DexYCB: A Benchmark for Capturing Hand Grasping of Objects

Y.-W. Chao, S. Birchfield, D. Fox, A. Handa, U. Iqbal, J. Kautz, P. Molchanov, J. Tremblay, Y. Xiang, W. Yang, Y. Narang

Computer Vision and Pattern Recognition (CVPR), Nashville, Tennessee, June 2021 (virtual)

Hierarchical Planning for Long-Horizon Manipulation with Geometric and Symbolic Scene Graphs

Y. Zhu, J. Tremblay, S. Birchfield, Y. Zhu

International Conference on Robotics and Automation (ICRA), Xi'an, China, May 2021 (virtual)

Fast Uncertainty Quantification for Deep Object Pose Estimation

G. Shi, Y. Zhu, J. Tremblay, S. Birchfield, F. Ramos, A. Anandkumar, Y. Zhu

International Conference on Robotics and Automation (ICRA), Xi'an, China, May 2021 (virtual)

NViSII: A Scriptable Tool for Photorealistic Image Generation

N. Morrical, J. Tremblay, Y. Lin, S. Tyree, S. Birchfield, V. Pascucci, I. Wald

ICLR Workshop on Synthetic Data Generation, Vienna, Austria, May 2021 (virtual)

RMPflow: A Geometric Framework for Generation of Multi-Task Motion Policies

C.-A. Cheng, M. Mukadam, J. Issac, S. Birchfield, D. Fox, B. Boots, N. Ratliff

IEEE Transactions on Automation Science and Engineering (T-ASE), 18(3):968-987, July 2021

2020

Contextual Reinforcement Learning of Visuo-tactile Multi-fingered Grasping Policies

V. Kumar, T. Hermans, D. Fox, S. Birchfield, J. Tremblay

NeurIPS Workshop on Robot Learning, December 2020 (virtual)

Indirect Object-to-Robot Pose Estimation from an External Monocular RGB Camera

J. Tremblay, S. Tyree, T. Mosier, S. Birchfield

International Conference on Intelligent Robots and Systems (IROS), Las Vegas, Nevada, October 2020 (virtual)

MVLidarNet: Real-Time Multi-Class Scene Understanding for Autonomous Driving Using Multiple Views

K. Chen, R. Oldja, N. Smolyanskiy, S. Birchfield, A. Popov, D. Wehr, I. Eden, J. Pehserl

International Conference on Intelligent Robots and Systems (IROS), Las Vegas, Nevada, October 2020 (virtual)

Camera-to-Robot Pose Estimation from a Single Image

T. E. Lee, J. Tremblay, T. To, J. Cheng, T. Mosier, O. Kroemer, D. Fox, S. Birchfield

International Conference on Robotics and Automation (ICRA), Paris, France, May 2020 (virtual)

Toward Sim-to-Real Directional Semantic Grasping

S. Iqbal, J. Tremblay, T. To, J. Cheng, E. Leitch, A. Campbell, K. Leung, D. McKay, S. Birchfield

International Conference on Robotics and Automation (ICRA), Paris, France, May 2020 (virtual)

DexPilot: Vision Based Teleoperation of Dexterous Robotic Hand-Arm System

A. Handa, K. Van Wyk, W. Yang, J. Liang, Y.-W. Chao, Q. Wan, S. Birchfield, N. Ratliff, D. Fox

International Conference on Robotics and Automation (ICRA), Paris, France, May 2020 (virtual)

Improving Deep Stereo Network Generalization with Geometric Priors

J. Wang, V. Jampani, D. Sun, C. Loop, S. Birchfield, J. Kautz

arXiv:2008.11098, August 2020

2019

PAMTRI: Pose-Aware Multi-Task Learning for Vehicle Re-Identification Using Highly Randomized Synthetic Data

Z. Tang, M. Naphade, S. Birchfield, J. Tremblay, W. Hodge, R. Kumar, S. Wang, X. Yang

International Conference on Computer Vision (ICCV), Seoul, South Korea, October 2019

Few-Shot Viewpoint Estimation

H.-Y. Tseng, S. De Mello, J. Tremblay, S. Liu, S. Birchfield, M.-H. Yang, J. Kautz

British Machine Vision Conference (BMVC), Cardiff, UK, September 2019

CityFlow: A City-Scale Benchmark for Multi-Target Multi-Camera Vehicle Tracking and Re-Identification

Z. Tang, M. Naphade, M.-Y. Liu, X. Yang, S. Birchfield, S. Wang, R. Kumar, D. Anastasiu, J.-N. Hwang

Computer Vision and Pattern Recognition (CVPR), Long Beach, California, June 2019

Robust Learning of Tactile Force Estimation through Robot Interaction

B. Sundaralingam, A. Lambert, A. Handa, B. Boots, T. Hermans, S. Birchfield, N. Ratliff, D. Fox

IEEE International Conference on Robotics and Automation (ICRA), Montreal, Canada, May 2019

Award: Best Robot Manipulation Paper Finalist

Structured Domain Randomization: Bridging the Reality Gap by Context-Aware Synthetic Data

A. Prakash, S. Boochoon, M. Brophy, D. Acuna, E. Cameracci, G. State, O. Shapira, S. Birchfield

IEEE International Conference on Robotics and Automation (ICRA), Montreal, Canada, May 2019

Multiple Hypothesis Tracking with Kinematics and Appearance Models on Traffic Flow for Wide Area Traffic Surveillance

X. Zhao, D. Dawson, W. A. Sarasua, S. Birchfield

ASCE Journal of Civil Engineering, 33(3), May 2019

2018

RMPflow: A Computational Graph for Automatic Motion Policy Generation

C.-A. Cheng, M. Mukadam, J. Issac, S. Birchfield, D. Fox, B. Boots, N. Ratliff

International Workshop on the Algorithmic Foundations of Robotics (WAFR), Mérida, México, December 2018

Deep Object Pose Estimation for Semantic Robotic Grasping of Household Objects

J. Tremblay, T. To, B. Sundaralingam, Y. Xiang, D. Fox, S. Birchfield

Conference on Robot Learning (CoRL), Zürich, Switzerland, October 2018

Press: NVIDIA, VentureBeat, ZDNet, Robot Report, HardOCP, Design World, rbr, R&A News, Sensors

Falling Things: A Synthetic Dataset for 3D Object Detection and Pose Estimation

J. Tremblay, T. To, S. Birchfield

CVPR Workshop on Real World Challenges and New Benchmarks for Deep Learning in Robotic Vision, Salt Lake City, Utah, June 2018

On the Importance of Stereo for Accurate Depth Estimation: An Efficient Semi-Supervised Deep Neural Network Approach

N. Smolyanskiy, A. Kamenev, S. Birchfield

CVPR Workshop on Autonomous Driving (WAD), Salt Lake City, Utah, June 2018

Training Deep Networks with Synthetic Data: Bridging the Reality Gap by Domain Randomization

J. Tremblay, A. Prakash, D. Acuna, M. Brophy, V. Jampani, C. Anil, T. To, E. Cameracci, S. Boochoon, S. Birchfield

CVPR Workshop on Autonomous Driving (WAD), Salt Lake City, Utah, June 2018

Synthetically Trained Neural Networks for Learning Human-Readable Plans from Real-World Demonstrations

J. Tremblay, T. To, A. Molchanov, S. Tyree, J. Kautz, S. Birchfield

IEEE International Conference on Robotics and Automation (ICRA), Brisbane, Australia, May 2018

Press: NVIDIA, TechCrunch, VentureBeat, Slash Gear, ZD Net

Region Growing Curriculum Generation for Reinforcement Learning

A. Molchanov, K. Hausman, S. Birchfield, G. Sukhatme

arXiv:1807.01425, July 2018

Riemannian Motion Policies

N. D. Ratliff, J. Issac, D. Kappler, S. Birchfield, D. Fox

arXiv:1801.02854, January 2018

2017

Automated Traffic Surveillance System with Aerial Camera Arrays Imagery: Macroscopic Data Collection with Vehicle Tracking

X. Zhao, D. Dawson, W. Sarasua, S. Birchfield

Journal of Computing in Civil Engineering, 31(3), 2017

Toward Low-Flying Autonomous MAV Trail Navigation using Deep Neural Networks for Environmental Awareness

N. Smolyanskiy, A. Kamenev, J. Smith, S. Birchfield

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Vancouver BC, Canada, September 2017

Reverse-Projection Method for Measuring Camera MTF

S. Birchfield

IS&T International Symposium on Electronic Imaging: Image Quality and System Performance XIV, January 2017

2015

RGBD Point Cloud Alignment Using Lucas-Kanade Data Association and Automatic Error Metric Selection

B. Peasley, S. Birchfield

IEEE Transactions on Robotics (T-RO), 31(6):1548-1554, December 2015

2014

Program Synthesis by Examples for Object Repositioning Tasks

A. Feniello, H. Dang, S. Birchfield

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Chicago, Illinois, September 2014

Occlusion-Aware Multi-View Reconstruction of Articulated Objects for Manipulation

X. Huang, I. Walker, S. Birchfield

Robotics and Autonomous Systems (RAS), 62(4):497-505, April 2014

Efficient Hierarchical Graph-Based Segmentation of RGBD Videos

S. Hickson, S. Birchfield, I. Essa, H. Christensen

IEEE Conference on Computer Vision and Pattern Recognition (CVPR), Columbus, Ohio, June 2014

Fast and Accurate PoseSLAM by Combining Relative and Global State Spaces

B. Peasley, S. Birchfield

IEEE International Conference on Robotics and Automation (ICRA), Hong Kong, China, May 2014

An Inexpensive Method for Evaluating the Localization Performance of a Mobile Robot Navigation System

H. Kikkeri, G. Parent, M. Jalobeanu, S. Birchfield

IEEE International Conference on Robotics and Automation (ICRA), Hong Kong, China, May 2014

2013

An Energy Minimization Approach to Automatic Traffic Camera Calibration Using MCMC

D. N. Dawson, S. Birchfield

IEEE Transactions on Intelligent Transportation Systems, 14(3):1095-1108, September 2013

Classification of Clothing Using Mid-Level Layers

B. Willimon, I. Walker, S. Birchfield

ISRN Robotics, vol. 2013, January 2013

A Person Follower Mobile Robot System for Indoor Environments

N. Pradhan, S. Birchfield, T. Burg

IROS Workshop on Assistance and Service Robotics in a Human Environment, Tokyo, Japan, November 2013

Indoor Navigation for Mobile Robots using Predictive Fields

N. Pradhan, T. Burg, S. Birchfield, U. Hasirci

American Control Conference (ACC), Washington, DC, June 2013

Replacing Projective Data Association with Lucas-Kanade for KinectFusion

B. Peasley, S. Birchfield

IEEE International Conference on Robotics and Automation (ICRA), Karlsruhe, Germany, May 2013

A New Approach to Clothing Classification using Mid-Level Layers

B. Willimon, I. Walker, S. Birchfield

IEEE International Conference on Robotics and Automation (ICRA), Karlsruhe, Germany, May 2013

3D Non-Rigid Deformable Surface Estimation Without Feature Correspondence

B. Willimon, I. Walker, S. Birchfield

IEEE International Conference on Robotics and Automation (ICRA), Karlsruhe, Germany, May 2013

Real-Time Obstacle Detection and Avoidance in the Presence of Specular Surfaces Using an Active 3D Sensor

B. Peasley, S. Birchfield

IEEE Workshop on Robot Vision (WoRV), Clearwater, Florida, January 2013

2012

Interactive Perception of Rigid and Non-Rigid Objects

B. Willimon, S. Birchfield, I. Walker

International Journal of Advanced Robotic Systems, vol. 9, September 2012

Autonomous Exploration Using Rapid Perception of Low-Resolution Image Information

V. N. Murali, S. Birchfield

Autonomous Robots, 32(2):115-128, February 2012

An Energy Minimization Approach to 3D Non-Rigid Deformable Surface Estimation Using RGBD Data

B. Willimon, S. Hickson, I. Walker, S. Birchfield

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Vilamoura, Portugal, October 2012

Accurate On-Line 3D Occupancy Grids Using Manhattan World Constraints

B. Peasley, S. Birchfield, A. Cunningham, F. Dellaert

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Vilamoura, Portugal, October 2012

Extracting Minimalistic Corridor Geometry from Low-Resolution Images

Y. Li, V. Murali, S. Birchfield

International Conference on Intelligent Robotics and Applications (ICIRA), Montreal, Quebec, Canada, October 2012

Occlusion-Aware Reconstruction and Manipulation of 3D Articulated Objects

X. Huang, I. Walker, S. Birchfield

IEEE International Conference on Robotics and Automation (ICRA), St. Paul, Minnesota, May 2012

2011

Development of an Automated Algorithm for Tracking and Quantifying Barnacle Cyprid Settlement Behavior

N. N. Pradhan, N. V. Gohad, B. Orihuela, T. C. Burg, S. Birchfield, D. Rittschof, A. S. Mount

Journal of Experimental Marine Biology and Ecology, volume 410, pages 21-28, December 2011

Visual Detection of Lintel-Occluded Doors by Integrating Multiple Cues Using a Data-Driven Markov Chain Monte Carlo Process

Z. Chen, Y. Li, S. Birchfield

Robotics and Autonomous Systems (RAS), 59(11):966-976, November 2011

Model for Unfolding Laundry using Interactive Perception

B. Willimon, S. Birchfield, I. Walker

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), San Francisco, California, September 2011

Robot Crowd Navigation using Predictive Position Fields in the Potential Function Framework

N. Pradhan, T. C. Burg, S. Birchfield

American Control Conference (ACC), San Francisco, California, July 2011

Classification of Clothing using Interactive Perception

B. Willimon, S. Birchfield, I. Walker

IEEE International Conference on Robotics and Automation (ICRA), Shanghai, China, May 2011

Evaluation of a Computer-Vision Tracking System for Collecting Traffic Data

N. K. Kanhere, S. Birchfield, W. A. Sarasua, S. Khoeini

Transportation Research Board Annual Meeting, Washington, D.C., January 2011

Fast image mosaicking using optical flow

K. Sapra, S. Birchfield

Proceedings of IEEE Southeastcon Conference, March 2011

2010

A Taxonomy and Analysis of Camera Calibration Methods for Traffic Monitoring Applications

N. K. Kanhere, S. Birchfield

IEEE Transactions on Intelligent Transportation Systems, 11(2):441-452, June 2010

Iris Segmentation in Non-Ideal Images Using Graph Cuts

S. Pundlik, S. Birchfield, D. Woodard

Image and Vision Computing, 28(12):1671-1681, December 2010

Traffic Monitoring of Motorcycles During Special Events Using Video Detection

N. K. Kanhere, S. Birchfield, W. A. Sarasua, S. Khoeini

Transportation Research Record: Journal of the Transportation Research Board, No. 2160, pp. 69-76, 2010
(presented at TRB Annual Meeting, Washington, D.C., January 2010)

Rapid Automated Detection of Roots in Minirhizotron Images

G. Zeng, S. Birchfield, C. E. Wells

Machine Vision and Applications, 21(3):309-317, April 2010

Vision-Based Path Following Without Calibration

Z. Chen, S. Birchfield

In Mobile Robots Navigation, ed. Alejandra Barrera, InTech, pages 427-446, March 2010 (ISBN 978-953-307-076-6)

Algorithm for Discriminating Aggregate Gaze Points: Comparison with Salient Regions-Of-Interest

T. J. Grindinger, V. N. Murali, S. Tetreault, A. T. Duchowski, S. Birchfield, P. Orero

International Workshop on Gaze Sensing and Interactions (IWGSI), Queenstown, New Zealand, November 2010

Image-Based Segmentation of Indoor Corridor Floors for a Mobile Robot

Y. Li, S. Birchfield

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Taipei, Taiwan, October 2010

Rigid and Non-Rigid Classification Using Interactive Perception

B. Willimon, S. Birchfield, I. Walker

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Taipei, Taiwan, October 2010

2009

Qualitative Vision-Based Path Following

Z. Chen, S. Birchfield

IEEE Transactions on Robotics (T-RO), 25(3):749-754, June 2009

Adaptive Fragments-Based Tracking of Non-Rigid Objects Using Level Sets

P. Chockalingam, N. Pradeep, S. Birchfield

International Conference on Computer Vision (ICCV), Kyoto, Japan, September 2009

Motion-Based View-Invariant Articulated Motion Detection and Pose Estimation Using Sparse Point Features

S. J. Pundlik, S. Birchfield

International Symposium on Visual Computing, Las Vegas, Nevada, November 2009

2008

Real-Time Motion Segmentation of Sparse Feature Points at Any Speed

S. J. Pundlik, S. Birchfield

IEEE Transactions on Systems, Man, and Cybernetics Part B: Cybernetics, 38(3):731-742, June 2008

Real-Time Incremental Segmentation and Tracking of Vehicles at Low Camera Angles Using Stable Features

N. K. Kanhere, S. Birchfield

IEEE Transactions on Intelligent Transportation Systems, 9(1):148-160, March 2008

Automatic Discrimination of Fine Roots in Minirhizotron Images

G. Zeng, S. Birchfield, C. E. Wells

New Phytologist, 177(2):549-557, January 2008

Automatic Camera Calibration Using Pattern Detection for Vision-Based Speed Sensing

N. K. Kanhere, S. Birchfield, W. A. Sarasua

Transportation Research Record: Journal of the Transportation Research Board, No. 2086, pp. 30-39, 2008
(presented at TRB Annual Meeting, Washington, D.C., January 2008)

Adapting Starburst for Elliptical Iris Segmentation

W. J. Ryan, D. L. Woodard, A. T. Duchowski, S. Birchfield

IEEE Second International Conference on Biometrics: Theory, Applications and Systems (BTAS), Washington, D.C., September 2008

Joint Tracking of Features and Edges

S. Birchfield, S. J. Pundlik

IEEE Conference on Computer Vision and Pattern Recognition (CVPR), Anchorage, Alaska, June 2008

Visual Detection of Lintel-Occluded Doors from a Single Image

Z. Chen, S. Birchfield

CVPR Workshop on Visual Localization for Mobile Platforms, Anchorage, Alaska, June 2008

Autonomous Navigation and Mapping Using Monocular Low-Resolution Grayscale Vision

V. N. Murali, S. Birchfield

CVPR Workshop on Visual Localization for Mobile Platforms, Anchorage, Alaska, June 2008

Non-Ideal Iris Segmentation Using Graph Cuts

S. J. Pundlik, D. L. Woodard, S. Birchfield

CVPR Workshop on Biometrics, Anchorage, Alaska, June 2008

Limbus/Pupil Switching for Wearable Eye Tracking Under Variable Lighting Conditions

W. J. Ryan, A. T. Duchowski, S. Birchfield

Symposium on Eye Tracking Research and Applications (ETRA), Savannah, Georgia, pages 61-64, March 2008

2007

Spatial Histograms for Region-Based Tracking

S. Birchfield, S. Rangarajan

Electronics and Telecommunications Research Institute (ETRI) Journal, 29(5):697-699, October 2007

Correspondence as Energy-Based Segmentation

S. Birchfield, B. Natarajan, C. Tomasi

Image and Vision Computing, 25(8):1329-1340, August 2007

Person Following with a Mobile Robot Using Binocular Feature-Based Tracking

Z. Chen, S. Birchfield

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), San Diego, California, pages 815-820, October 2007

Isomap Tracking with Particle Filtering

N. Rane, S. Birchfield

IEEE International Conference on Image Processing (ICIP), San Antonio, Texas, vol. 2, pages 513-516, September 2007

Real-Time Detection and Tracking of Vehicle Base Fronts for Measuring Traffic Counts and Speeds on Highways

N. K. Kanhere, S. Birchfield, W. A. Sarasua, T. C. Whitney

Transportation Research Record: Journal of the Transportation Research Board, No. 1993, pp. 155-164, 2007
(presented at TRB Annual Meeting, Washington, D.C., January 2007)

2006

Detecting and Measuring Fine Roots in Minirhizotron Images Using Matched Filtering and Local Entropy Thresholding

G. Zeng, S. Birchfield, C. E. Wells

Machine Vision and Applications, 17(4):265-278, 2006

Motion Segmentation at Any Speed

S. J. Pundlik, S. Birchfield

British Machine Vision Conference (BMVC), Edinburgh, Scotland, pages 427-436, September 2006

Qualitative Vision-Based Mobile Robot Navigation

Z. Chen, S. Birchfield

IEEE International Conference on Robotics and Automation (ICRA), Orlando, Florida, pages 2686-2692, May 2006

Vehicle Segmentation and Tracking in the Presence of Occlusions

N. K. Kanhere, S. Birchfield, W. A. Sarasua

Transportation Research Record: Journal of the Transportation Research Board, No. 1944, pp. 89-97, 2006
(presented at TRB Annual Meeting, Washington, D.C., January 2006)

Automated Patient Facial Image Capture to Reduce Medical Error

C. Feied, M. Gillam, J. Handler, S. Birchfield

American Medical Informatics Association (AMIA) Annual Symposium, Washington DC, November 2006

Automatic Detection of Fine Roots in Minirhizotron Images

G. Zeng, S. Birchfield, C. Wells, D. Layne

American Society for Horticultural Science (ASHS) Annual Conference, New Orleans, Louisiana, July 2006

GIS-Based Roadway Video-logging using a Firewire Camera Combined with Satellite Differentially Corrected GPS

W. Sarasua, N. Kanhere, S. Birchfield

19th Geospatial Information Systems for Transportation Symposium, Columbus, Ohio, March 2006

2005

Microphone Array Position Calibration by Basis-Point Classical Multidimensional Scaling

S. Birchfield, A. Subramanya

IEEE Transactions on Speech and Audio Processing, 13(5):1025-1034, September 2005

Spatiograms Versus Histograms for Region-Based Tracking

S. Birchfield, S. Rangarajan

IEEE Conference on Computer Vision and Pattern Recognition (CVPR), San Diego, California, volume 2, pages 1158-1163, June 2005

Vehicle Segmentation and Tracking from a Low-Angle Off-Axis Camera

N. K. Kanhere, S. J. Pundlik, S. Birchfield

IEEE Conference on Computer Vision and Pattern Recognition (CVPR), San Diego, California, volume 2, pages 1152-1157, June 2005

Analysis of Neurite Outgrowth for a Laser Patterned Neuronal Culture

S. K. Guduru, S. V. Narasimhan, S. Birchfield, B. Z. Gao

2nd International IEEE EMBS Special Topic Conference on Neural Engineering, Arlington, Virginia, March 2005

Acoustic Localization by Interaural Level Difference

S. Birchfield, R. Ganghishetty

IEEE International Conference on Acoustics, Speech, and Signal Processing (ICASSP), Philadelphia, Pennsylvania, vol. 4, pages 1109-1112, March 2005

2004

A Unifying Framework for Acoustic Localization

S. Birchfield

12th European Signal Processing Conference (EUSIPCO), Vienna, Austria, September 2004

Extension and Evaluation of MDS for Geometric Microphone Array Calibration

A. Subramanya, S. Birchfield

12th European Signal Processing Conference (EUSIPCO), Vienna, Austria, September 2004

2003

Geometric Microphone Array Calibration by Multidimensional Scaling

S. Birchfield

IEEE International Conference on Acoustics, Speech, and Signal Processing (ICASSP), Hong Kong, April 2003

2002

Fast Bayesian Acoustic Localization

S. Birchfield, D. K. Gillmor

IEEE International Conference on Acoustics, Speech, and Signal Processing (ICASSP), Orlando, Florida, May 2002

2001

Acoustic Source Direction by Hemisphere Sampling

S. Birchfield, D. K. Gillmor

IEEE International Conference on Acoustics, Speech, and Signal Processing (ICASSP), Salt Lake City, Utah, May 2001

1999

Depth and Motion Discontinuities

S. Birchfield

Ph.D. dissertation, Stanford University, June 1999

Depth Discontinuities by Pixel-to-Pixel Stereo

S. Birchfield, C. Tomasi

International Journal of Computer Vision (IJCV), 35(3):269-293, December 1999

Multiway Cut for Stereo and Motion with Slanted Surfaces

S. Birchfield, C. Tomasi

Seventh IEEE International Conference on Computer Vision (ICCV), Kerkyra, Greece, pages 489-495, September 1999

1998

A Pixel Dissimilarity Measure That is Insensitive To Image Sampling

S. Birchfield, C. Tomasi

IEEE Transactions on Pattern Analysis and Machine Intelligence (PAMI), 20(4):401-406, April 1998

Elliptical Head Tracking Using Intensity Gradients and Color Histograms

S. Birchfield

IEEE Conference on Computer Vision and Pattern Recognition (CVPR), Santa Barbara, California, pages 232-237, June 1998

Depth Discontinuities by Pixel-to-Pixel Stereo

S. Birchfield, C. Tomasi

Sixth IEEE International Conference on Computer Vision (ICCV), Mumbai, India, pages 1073-1080, January 1998

1997

An Elliptical Head Tracker

S. Birchfield

31st Asilomar Conference on Signals, Systems, and Computers, Pacific Grove, California, pages 1710-1714, November 1997

1996

Depth Discontinuities by Pixel-to-Pixel Stereo

S. Birchfield, C. Tomasi

Stanford University Technical Report STAN-CS-TR-96-1573, July 1996
1995

Dervish: An Office Navigating Robot

I. Nourbakhsh, R. Powers, S. Birchfield

AI Magazine, 16(2):53-60, Summer 1995